Product leader · autonomy · AI
I build products that make autonomy and AI useful in the physical world.
Product leader across autonomous transportation, instant logistics, intelligent travel, and applied robotics.
 Udacity
01 · Professional
Professional
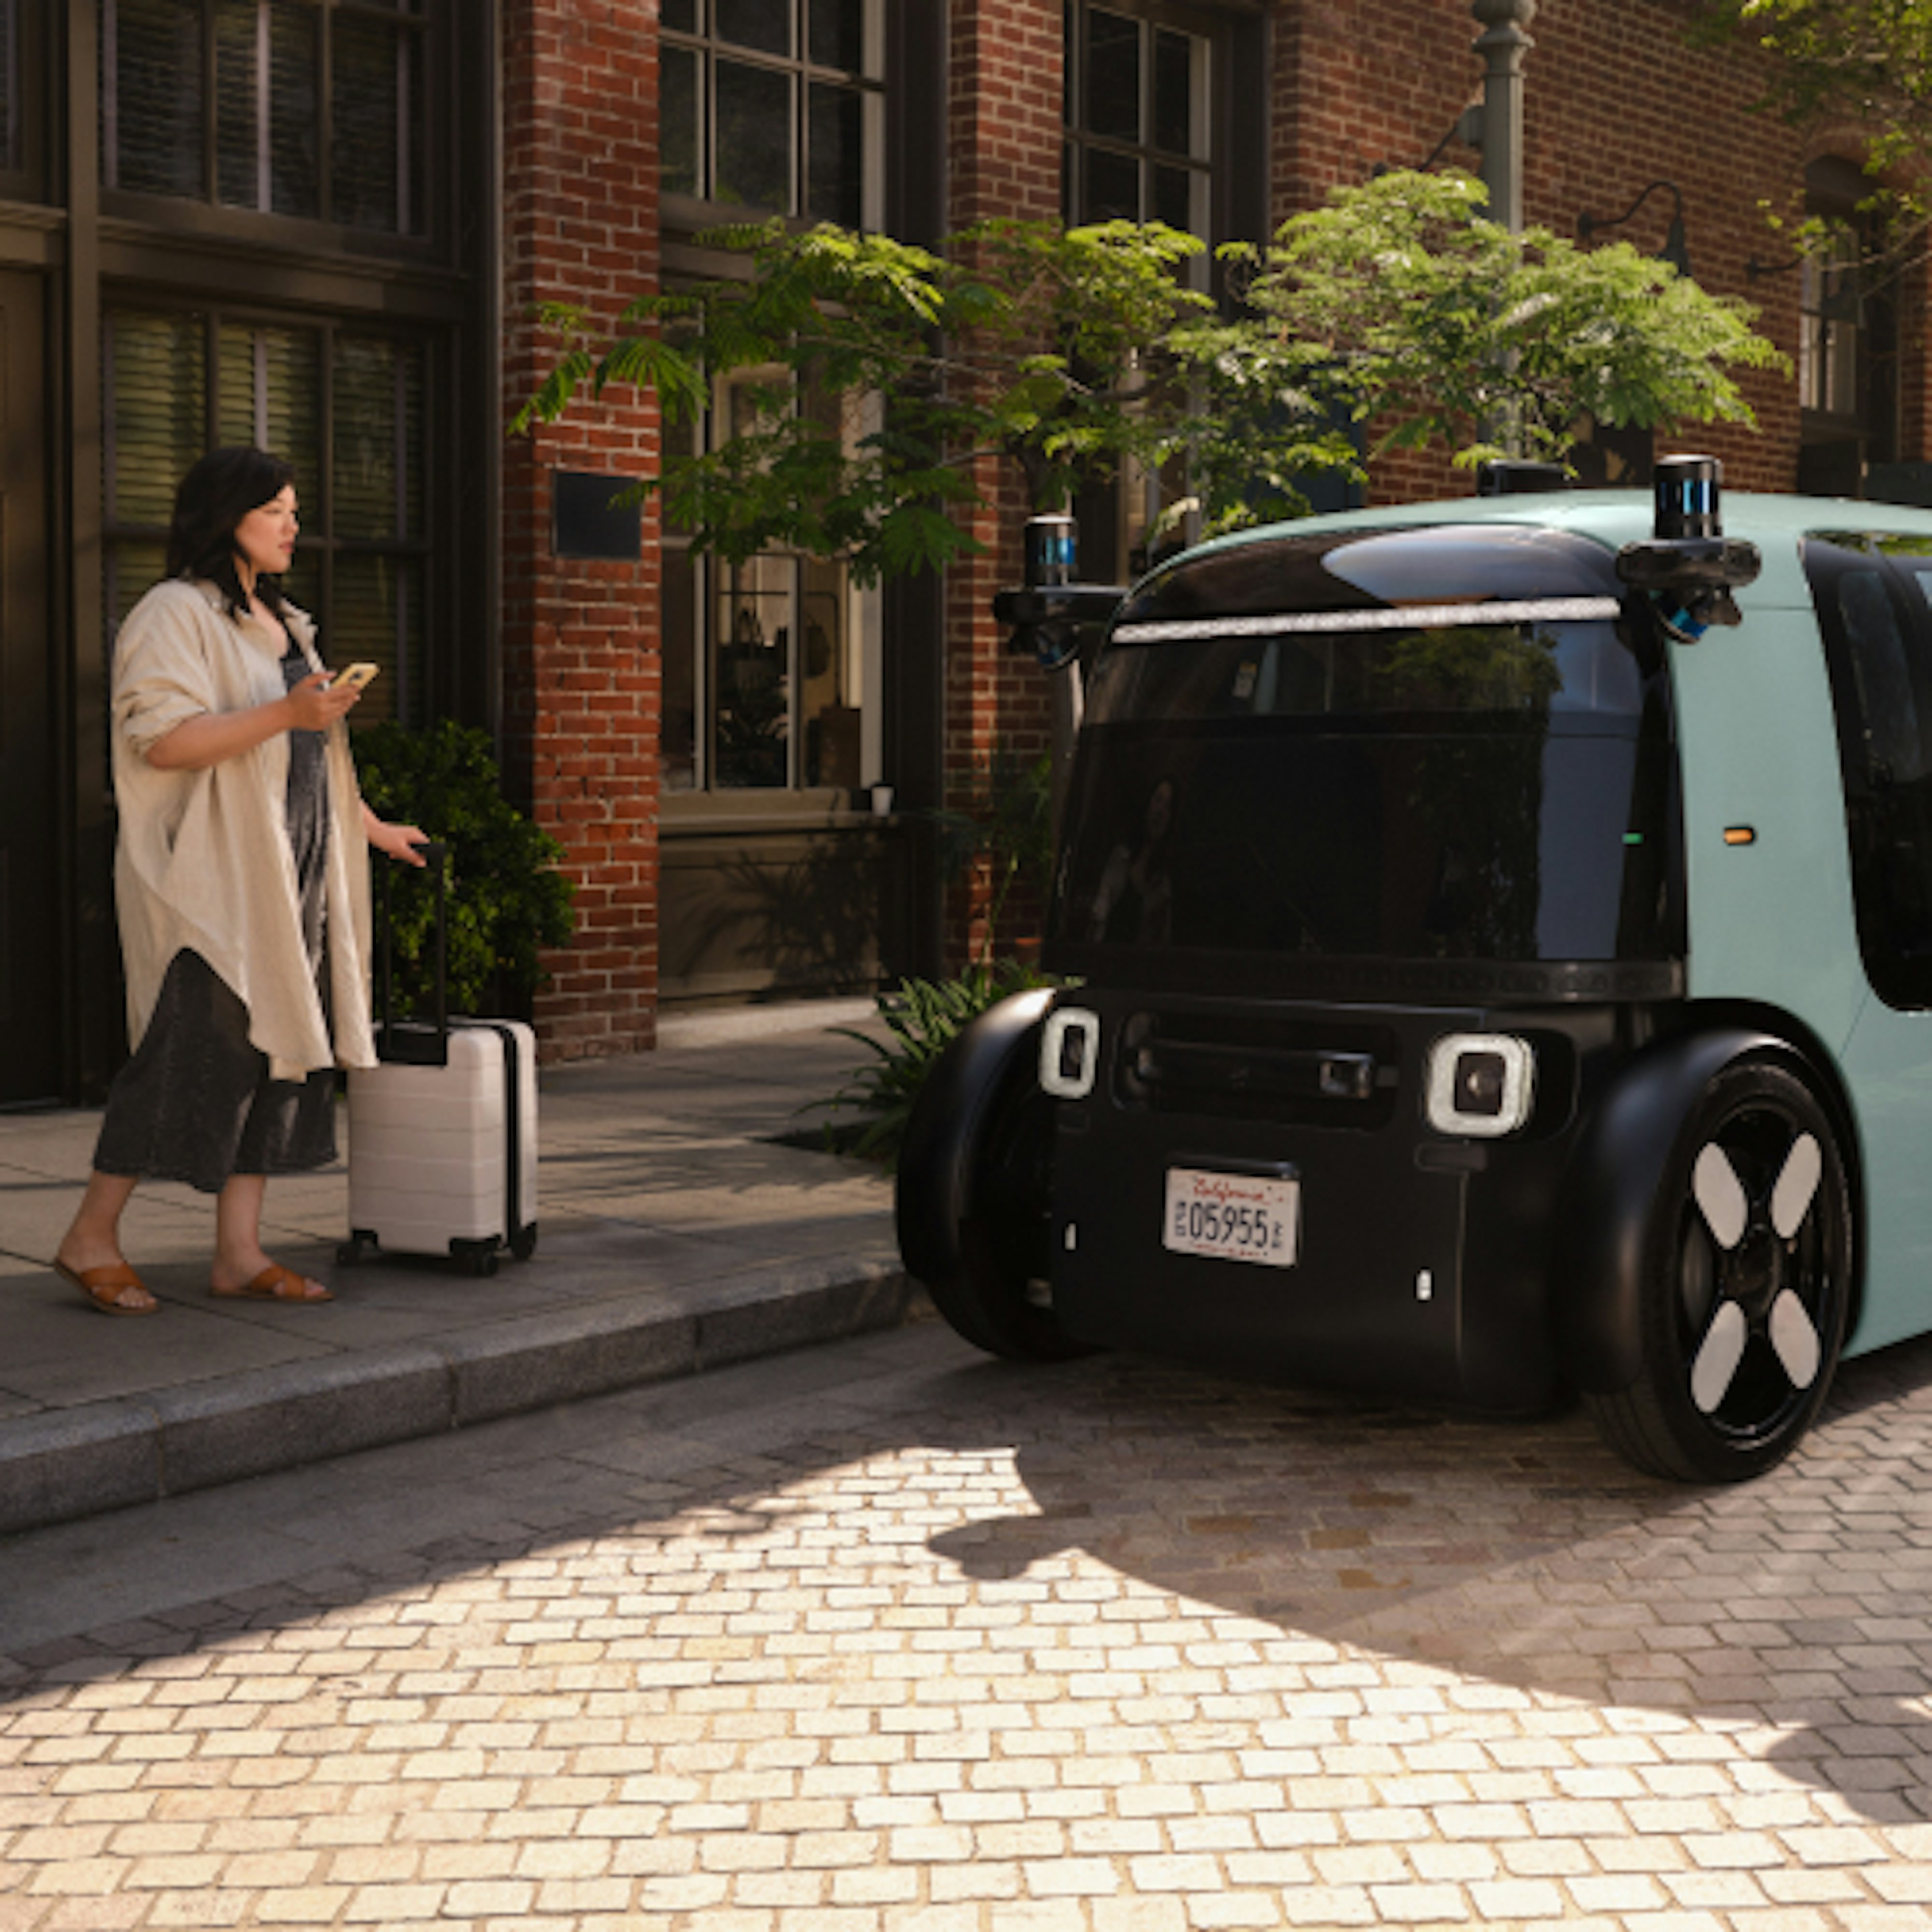
As the first PM on Zoox’s autonomy team, I established the product function and owned pickup/dropoff strategy that helped deliver a 100× improvement in rider convenience.
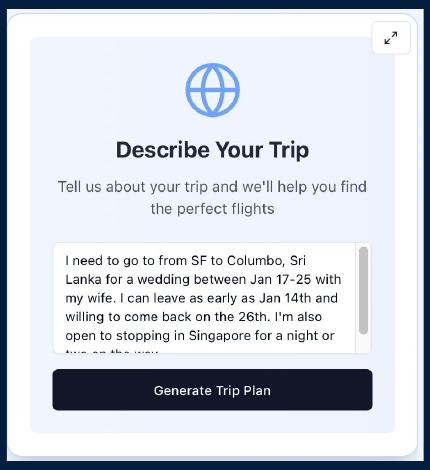
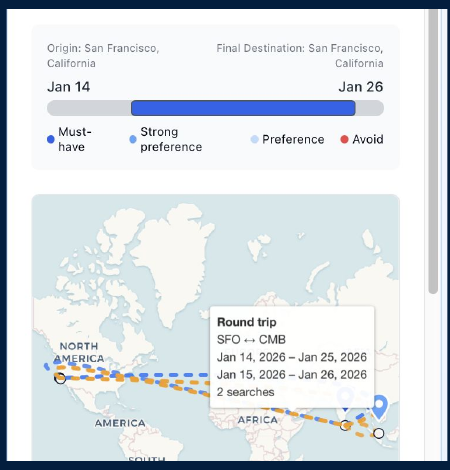
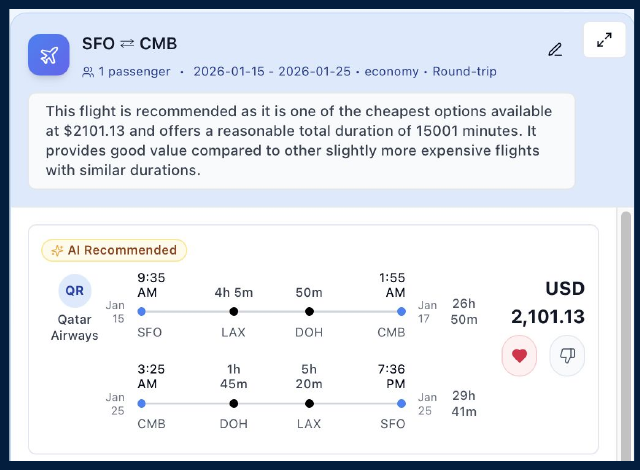
I built an agentic flight-planning experience that turns free-form traveler needs into personalized itineraries and recommendations.
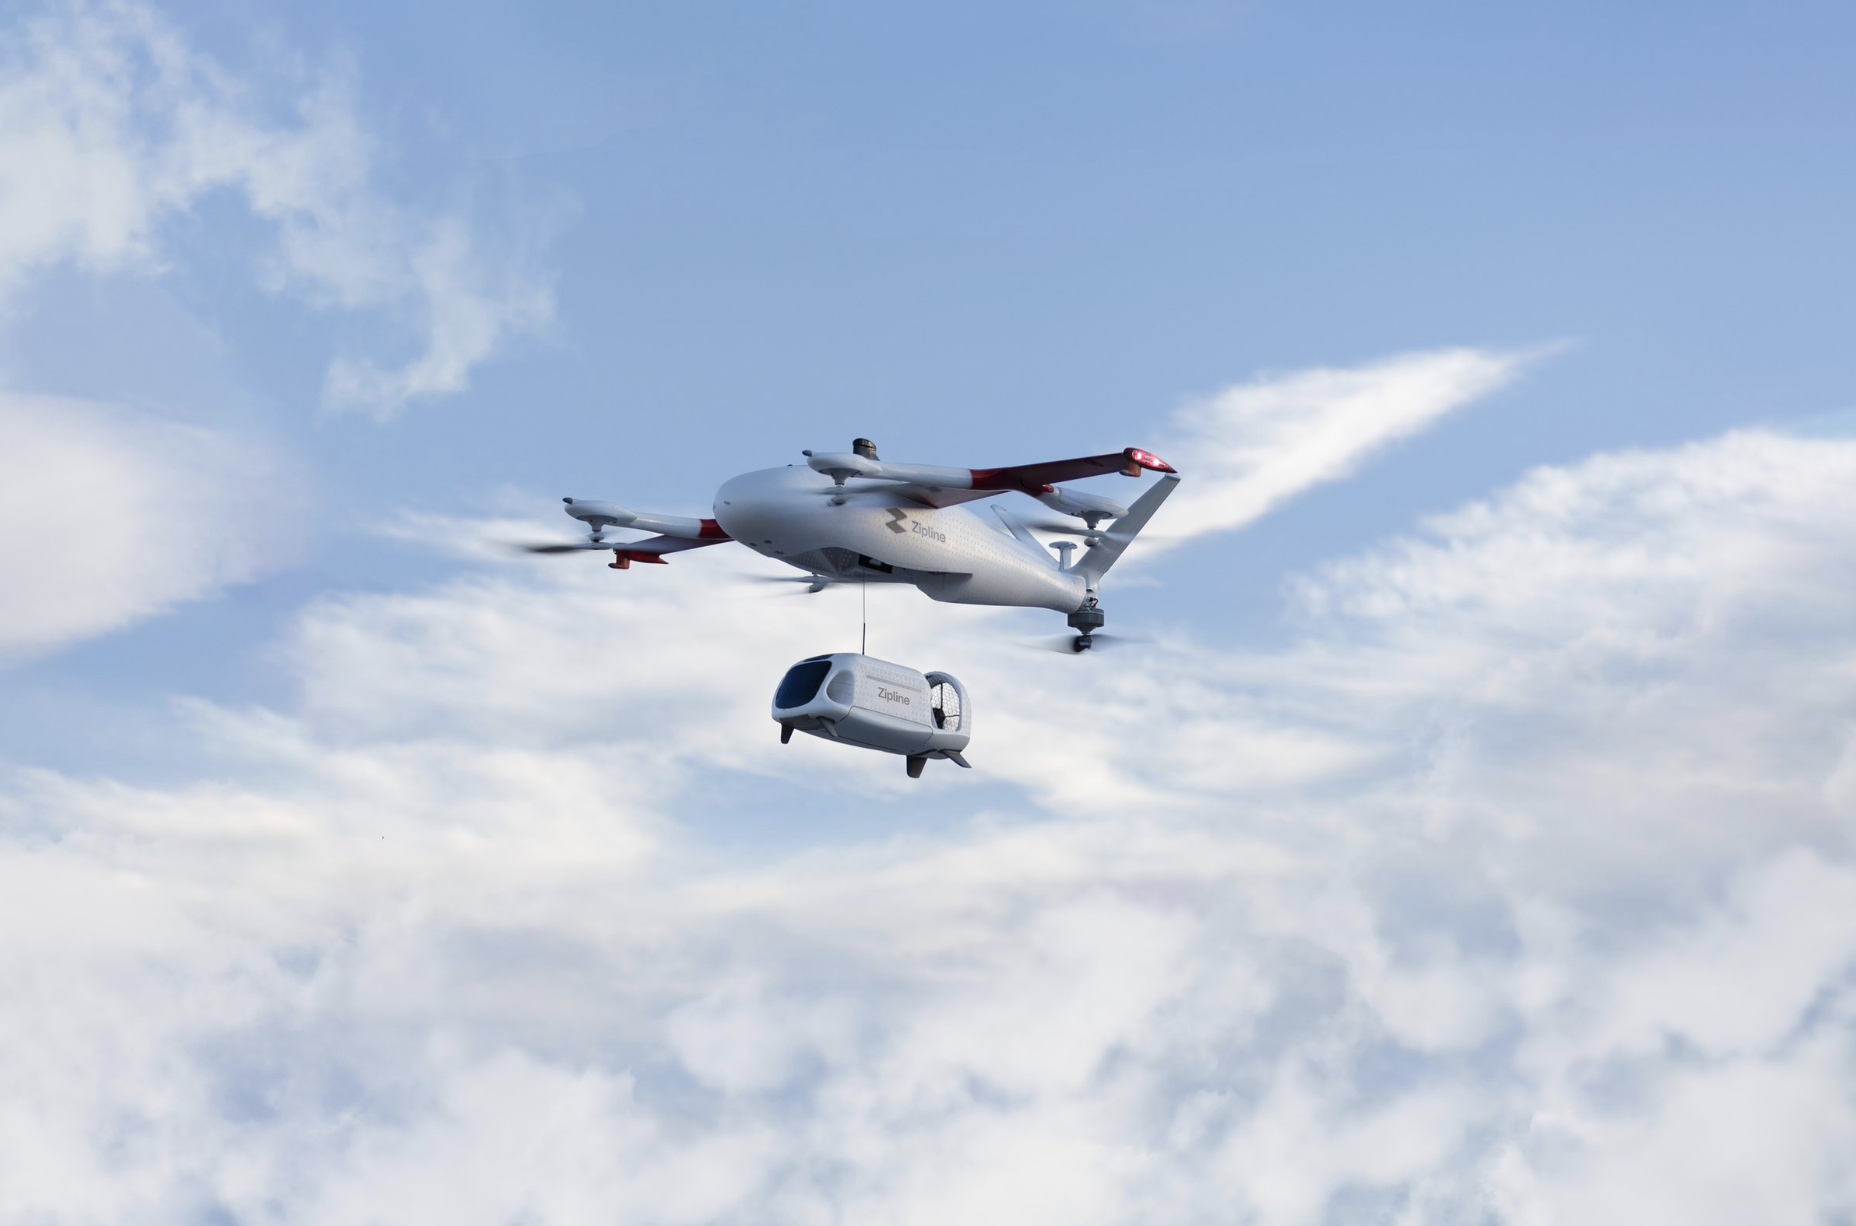
Visit Blue Saga AII used simulation-based configuration analysis to define Platform 2 requirements, saving months of build-test iteration as Zipline scaled instant logistics from rural delivery to suburban markets.
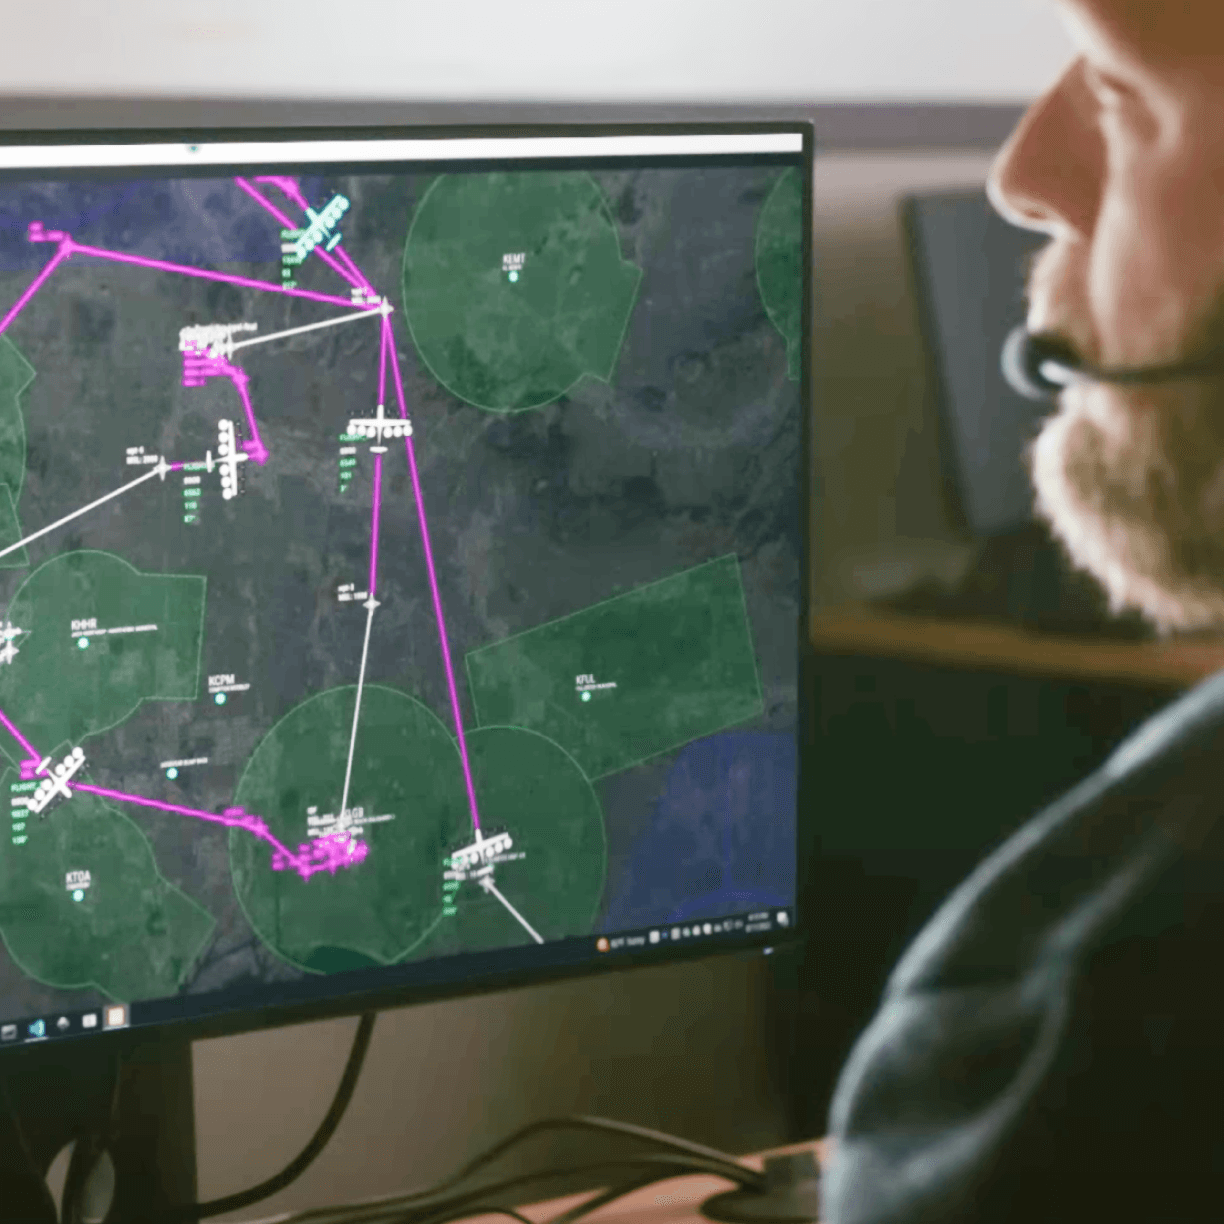
I defined Wisk’s first comprehensive autonomy requirements across onboard automation, operator responsibilities, mission planning, and enabling technologies—laying the foundation for full-scale remote operations.
I launched 3 projects plus two simulators and the Udacidrone Python API package, helping thousands of students worldwide learn about aerial autonomy through simulation.
02 · Academic
Academic
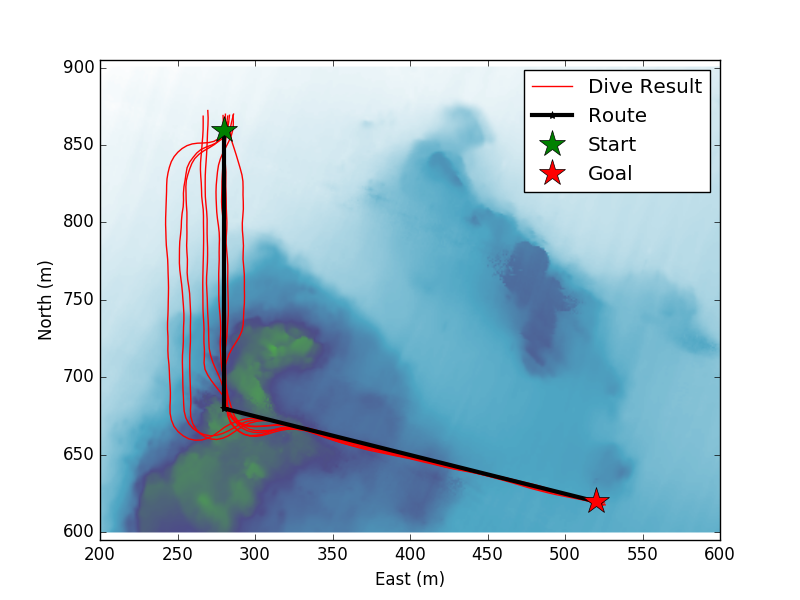
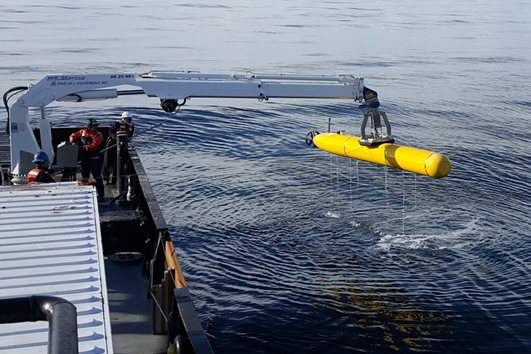
I developed route-planning algorithms for AUV return-to-site missions to reduce navigational uncertainty and improve mission success in deep-ocean-floor monitoring for scientific missions.
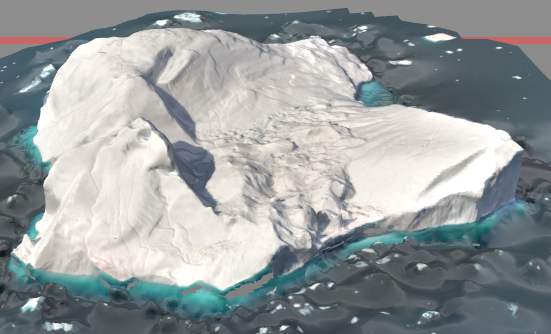
I built the above-water 3D model used to tag and track the iceberg; I supported underwater mapping analysis and robotic navigation during a scientific expedition to Sermilik Fjord, Greenland.
I worked on autonomous search and rescue using quadcopters; the team placed second in the 2016 challenge.
View the project03 · Personal
Personal
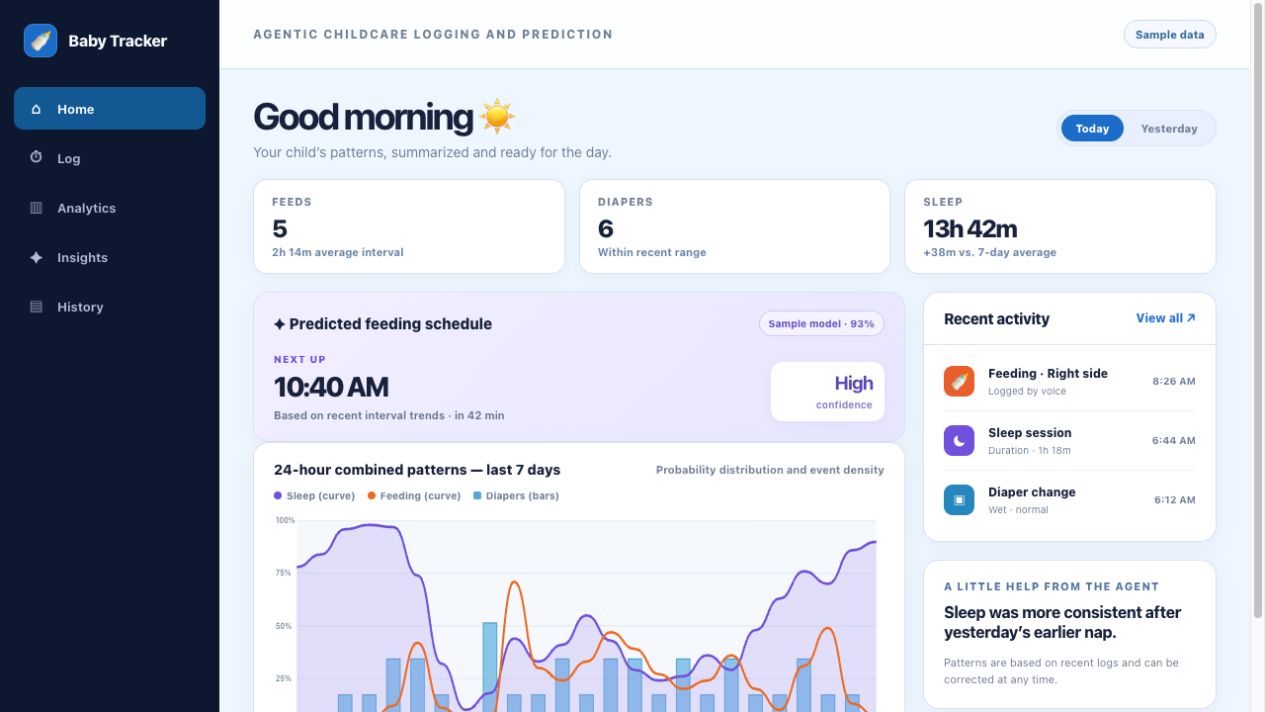
Utilizing AI Agents to improve my everyday.
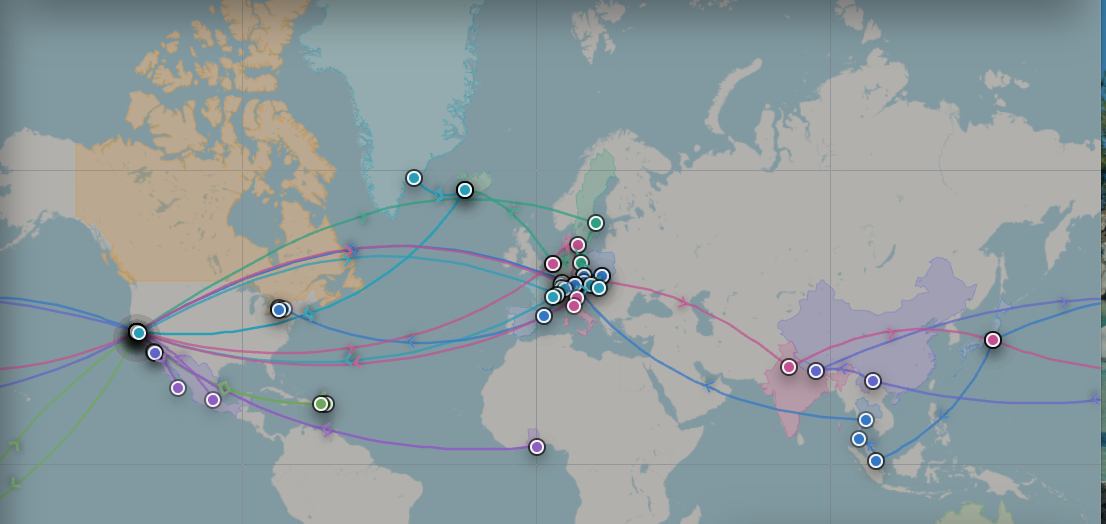
A personal map for logging and tracking travel.
View the live demo